Floorplan parsing
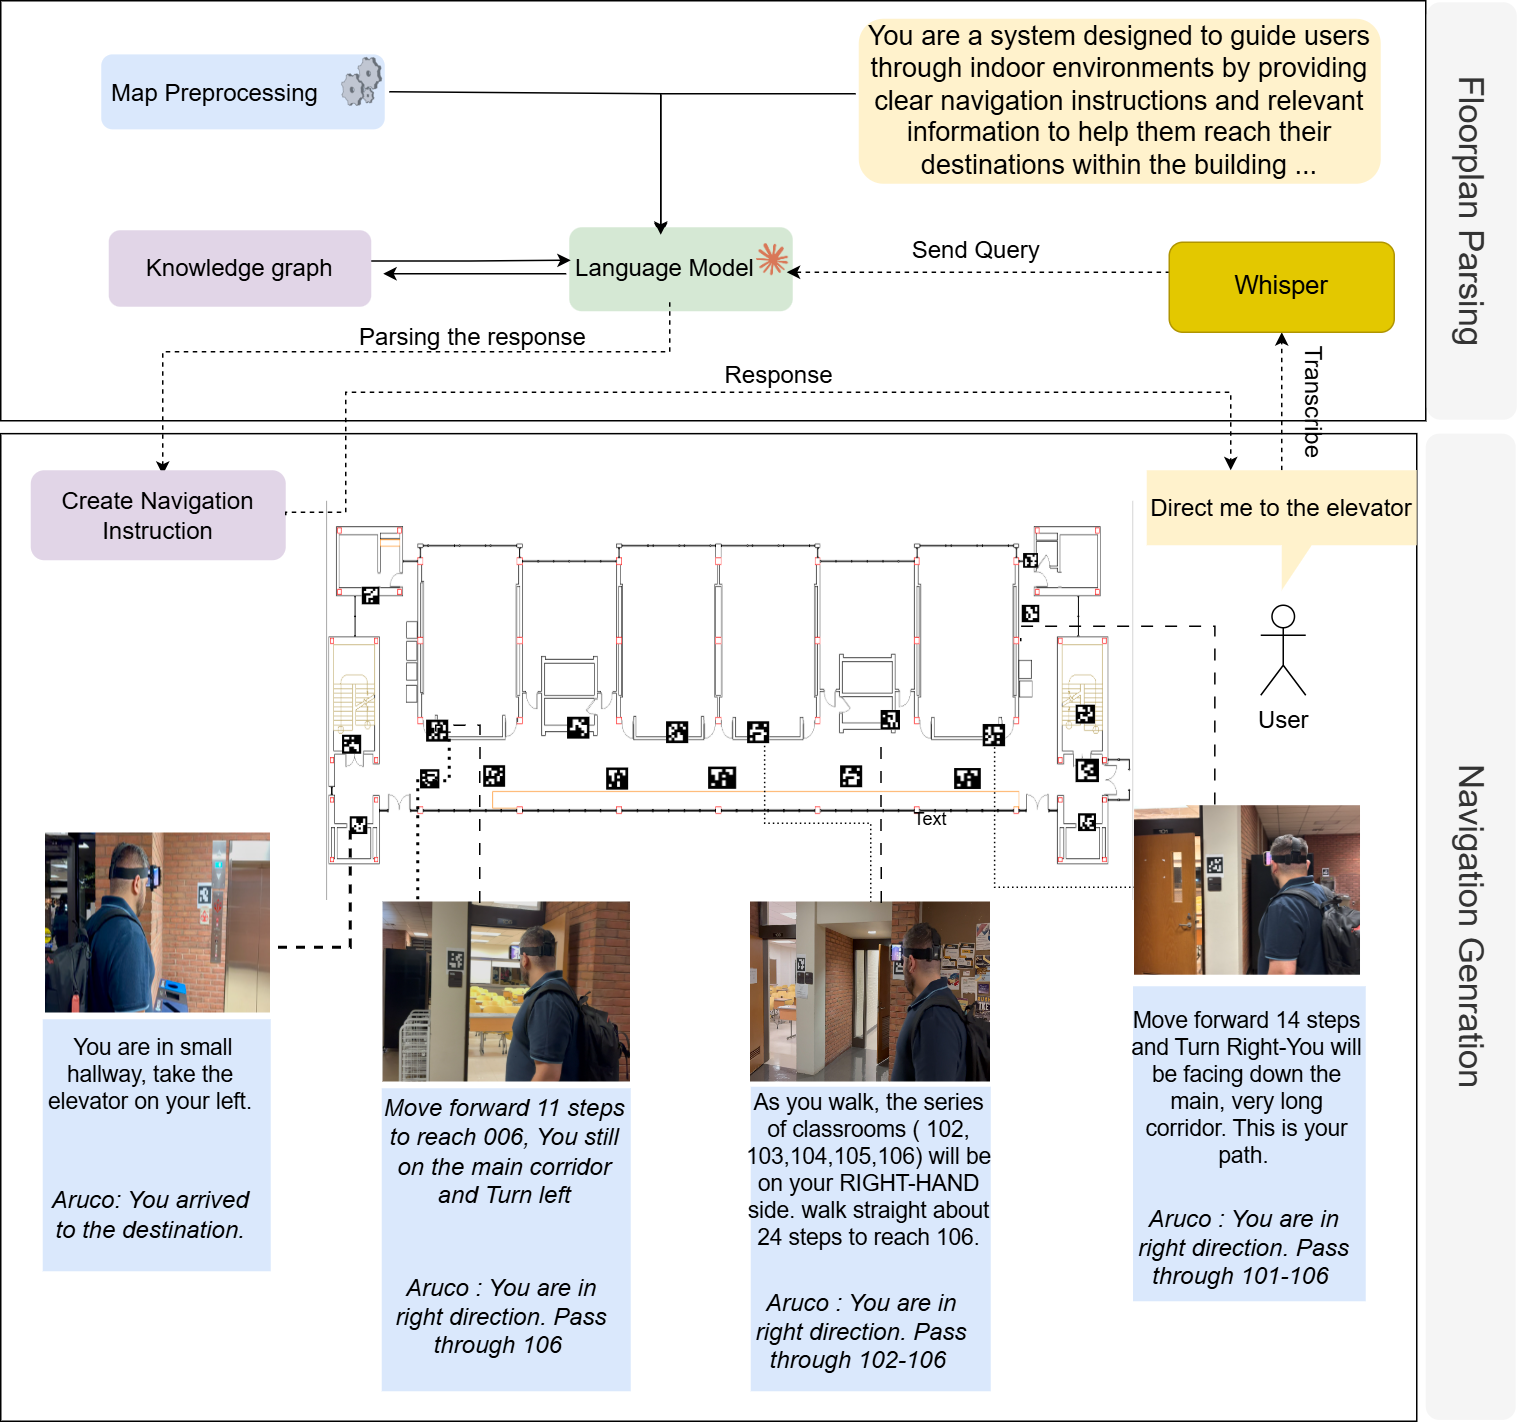
Textual and geometric features are extracted from architectural layouts using OCR and visual analysis.
IEEE BigData 2025
1 University of Maryland, Baltimore County
Indoor navigation remains a critical challenge for people with visual impairments. The current solutions mainly rely on infrastructure-based systems, which limit their ability to navigate safely in dynamic environments. We propose a novel navigation approach that utilizes a foundation model to transform floor plans into navigable knowledge graphs and generate human-readable navigation instructions. Floorplan2Guide integrates a large language model (LLM) to extract spatial information from architectural layouts, reducing the manual preprocessing required by earlier floorplan parsing methods. Experimental results indicate that few-shot learning improves navigation accuracy in comparison to zero-shot learning on simulated and real-world evaluations. Claude 3.7 Sonnet achieves the highest accuracy among the evaluated models, with 92.31%, 76.92%, and 61.54% on the short, medium, and long routes, respectively, under 5-shot prompting of the MP-1 floor plan. The success rate of graph-based spatial structure is 15.4% higher than that of direct visual reasoning among all models, which confirms that graphical representation and in-context learning enhance navigation performance and make our solution more precise for indoor navigation of Blind and Low Vision (BLV) users.
Textual and geometric features are extracted from architectural layouts using OCR and visual analysis.
The language model constructs and validates a graph of spatial entities and their connections, enriched with ArUco marker information.
User queries are translated into step-by-step, context-aware indoor navigation instructions.
Marker-based localization supports route tracking and alerts users when they deviate from the planned route.
@inproceedings{ayanzadeh2025floorplan2guide,
  title     = {Floorplan2Guide: LLM-Guided Floorplan Parsing for BLV Indoor Navigation},
  author    = {Ayanzadeh, Aydin and Oates, Tim},
  booktitle = {2025 IEEE International Conference on Big Data (BigData)},
  pages     = {7477--7485},
  year      = {2025},
  doi       = {10.1109/BigData66926.2025.11401868}
}